A Unitree G1 humanoid, at your event
For events, exhibitions, universities and shoots. Every job starts with a conversation about your event, then an itemised quotation from us.
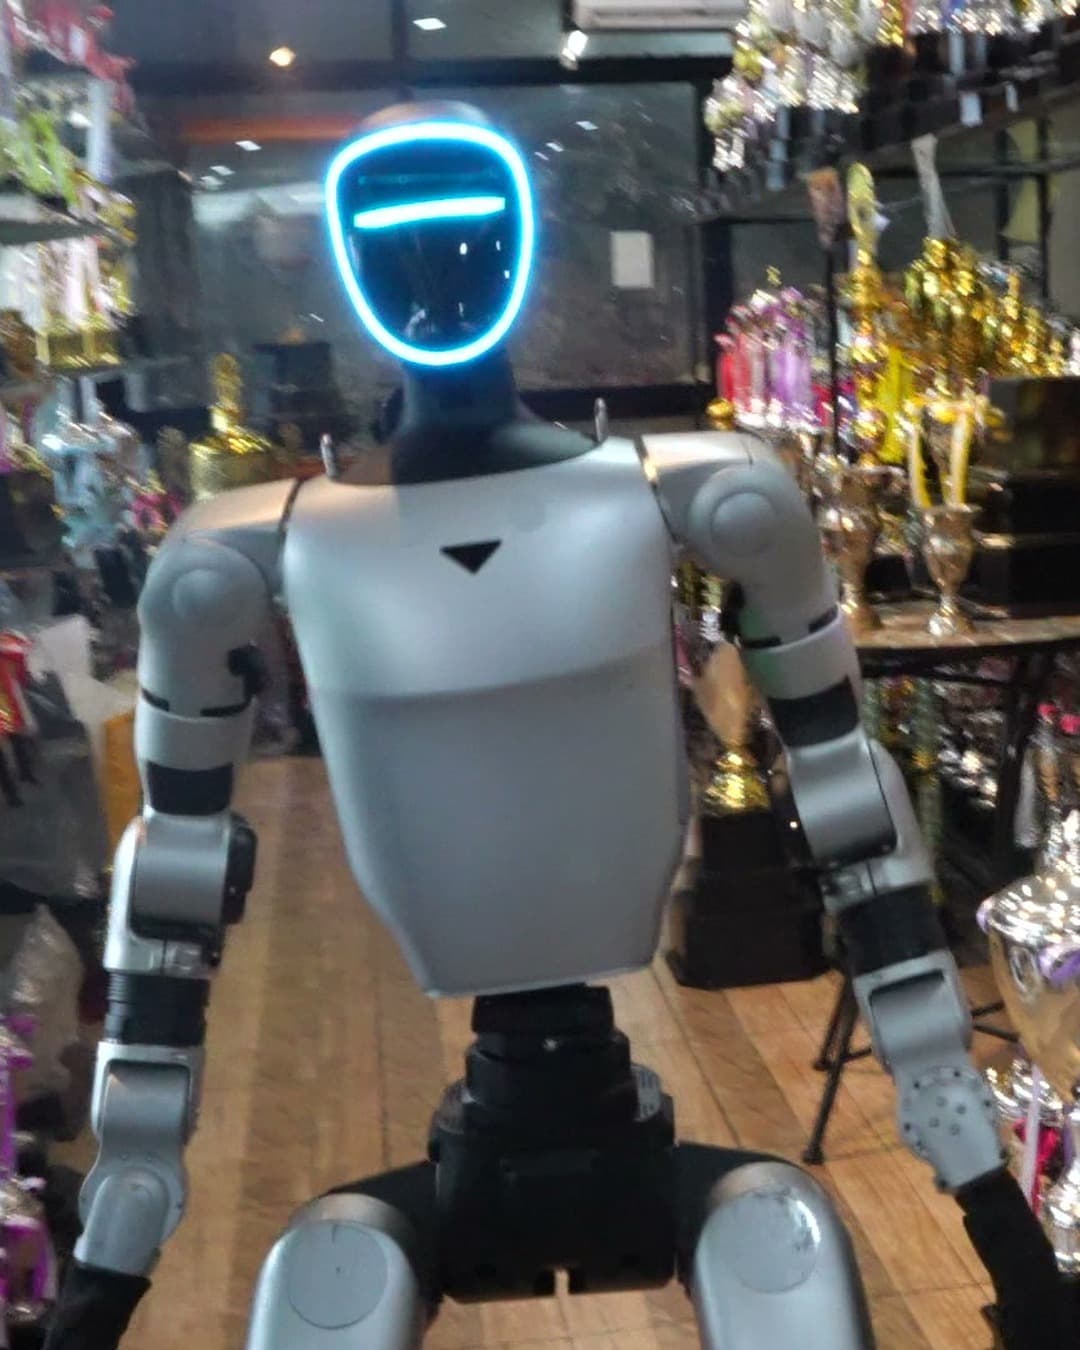
The G1 in numbers
- Standing height
1320mm
- Weight with battery
~35+kg
- Degrees of freedom per leg
6
- Quick-release battery
9000mAh
Figures from unitree.com/g1, checked 5 October 2026. The full sheet and its sources are below.
What we can and can’t do yet
Wongsaphat Puangsorn, co-founder, operates the robot in person throughout the show, with its remote control on him.
Can do
- Check the date and venue you send us, with the deposit and payment terms set out in the quotation
- Send an itemised quotation before every job
Can’t do yet
- Routines programmed specially for your event
- Unscripted conversation with guests through AI
- Performing without an operator
- Picking up or handing over items: its hands are fixed and can’t grip
Unitree G1 EDU specs
These are the specs of the G1 we bring to your event. Each figure comes from a source named under the tables, and Unitree notes that its figures can vary with the conditions of use and the robot’s configuration.
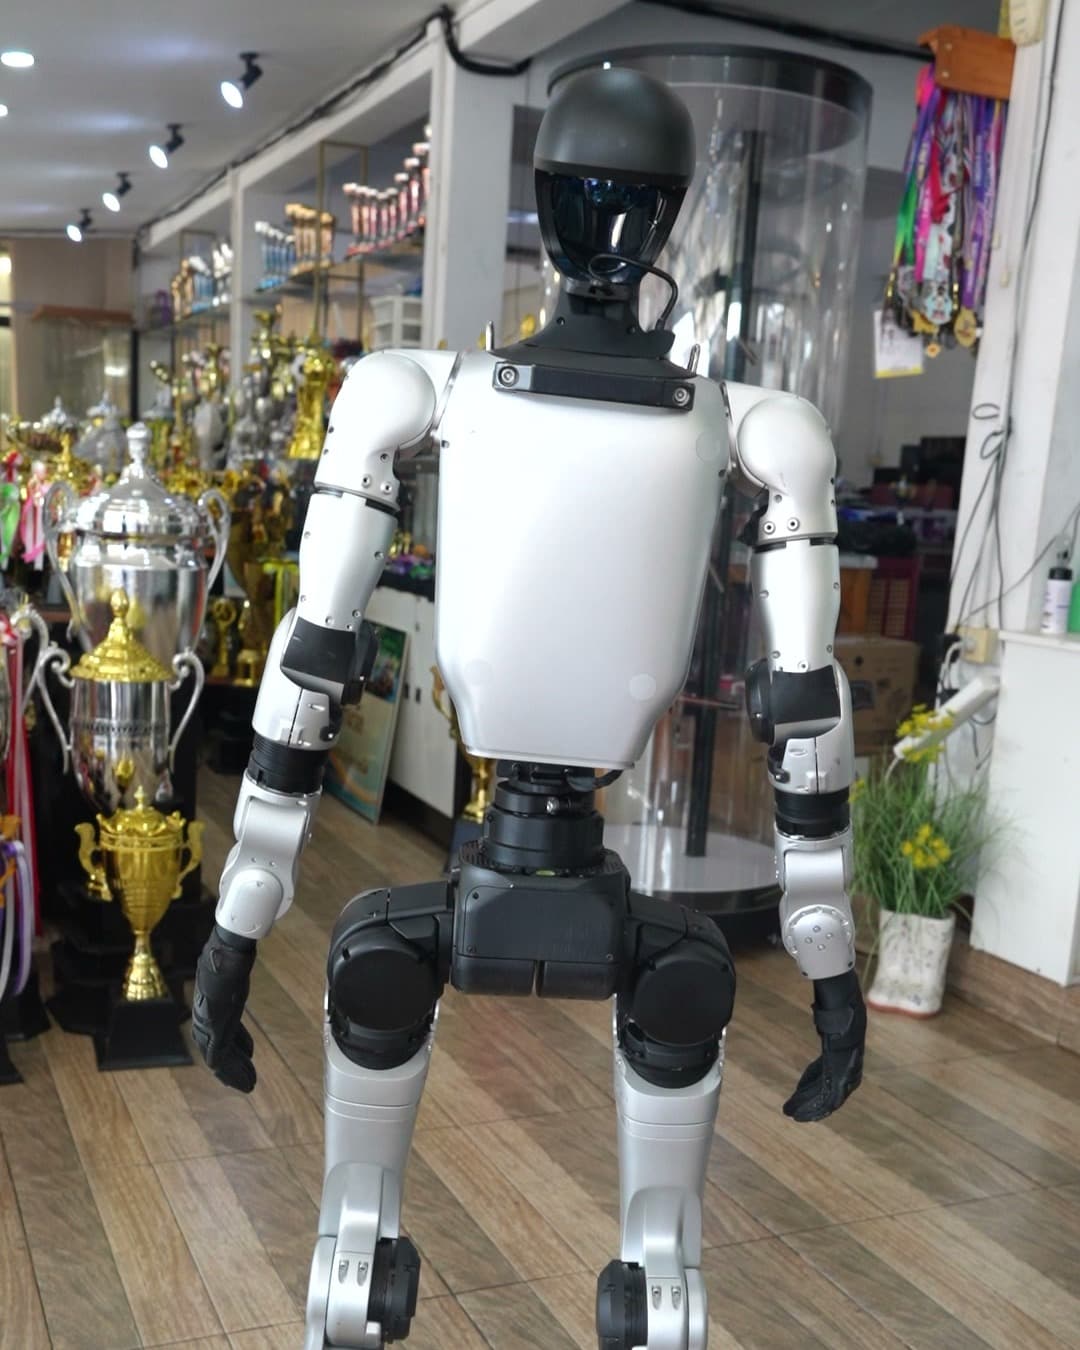
| Height × width × thickness (standing) | 1320 × 450 × 200 mm |
|---|---|
| Height × width × thickness (folded) | 690 × 450 × 300 mm |
| Weight with battery | ~35 kg+ |
| Calf and thigh length | 0.6 m |
| Arm span | ~0.45 m |
| Total degrees of freedom | 29 |
|---|---|
| Degrees of freedom per leg | 6 |
| Waist degrees of freedom | 3 |
| Degrees of freedom per arm (wrist included) | 7 |
| Waist joint range | Z ±155°, X ±30°, Y ±30° |
| Knee joint range | 0° to 165° |
| Hip joint range | P ±154°, R −30° to +170°, Y ±158° |
| Wrist joint range | P ±92.5°, Y ±92.5° |
| Maximum knee joint torque | 120 N·m* |
|---|---|
| Maximum arm load | ~3 kg† |
| Battery life | ~2 h‡ |
|---|---|
| Battery capacity (quick-release battery) | 9000 mAh |
| Lithium battery, cells in series | 13 |
| Charger voltage | 54 V |
| Charger current | 5 A |
| CPU cores | 8 |
|---|---|
| AI computing dock | 100 TOPS |
| Sensors | Depth camera and 3D LiDAR |
| Microphones (array) | 4 |
|---|---|
| Speaker power | 5 W |
| Wireless | Wi-Fi 6 and Bluetooth 5.2 |
| Joint output bearings | Industrial-grade crossed roller bearings |
|---|---|
| Joint motors | Low-inertia internal-rotor PMSM |
| Joint encoders | Dual encoders |
| Cooling | Local air cooling |
| Wiring | Routed through every joint’s hollow core |
Sources: Unitree Robotics, unitree.com/g1 (checked 5 October 2026); STA Robotics, stabots.com, for the G1 EDU U2 build’s total degrees of freedom, waist degrees of freedom, degrees of freedom per arm and AI computing dock (checked 5 October 2026)
- * Unitree notes that the joint motors differ in maximum torque, and gives this figure for the largest of them.
- † Unitree notes that this changes a great deal with how far the arm is extended.
- ‡ Depends on movements, temperature and number of shows.
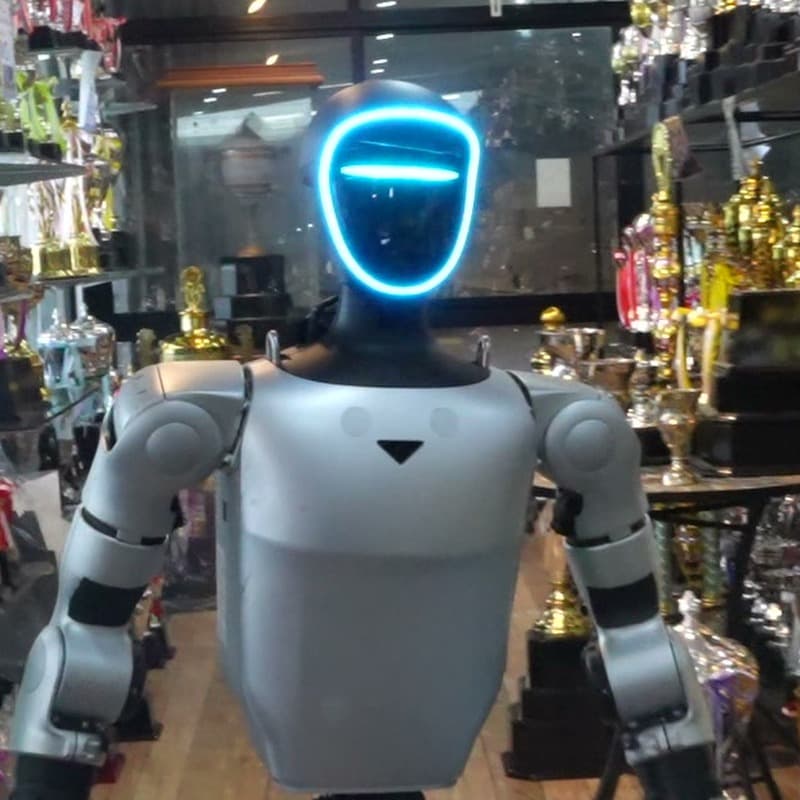
Photo: Thaibotic, Pathum Thani, November 2026 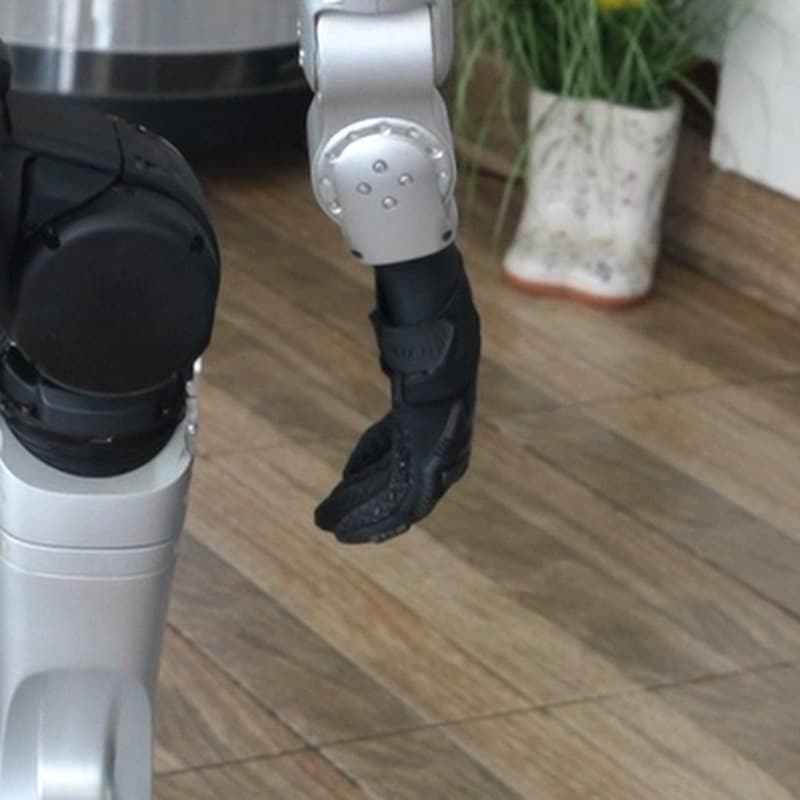
Photo: Thaibotic, Pathum Thani, November 2026 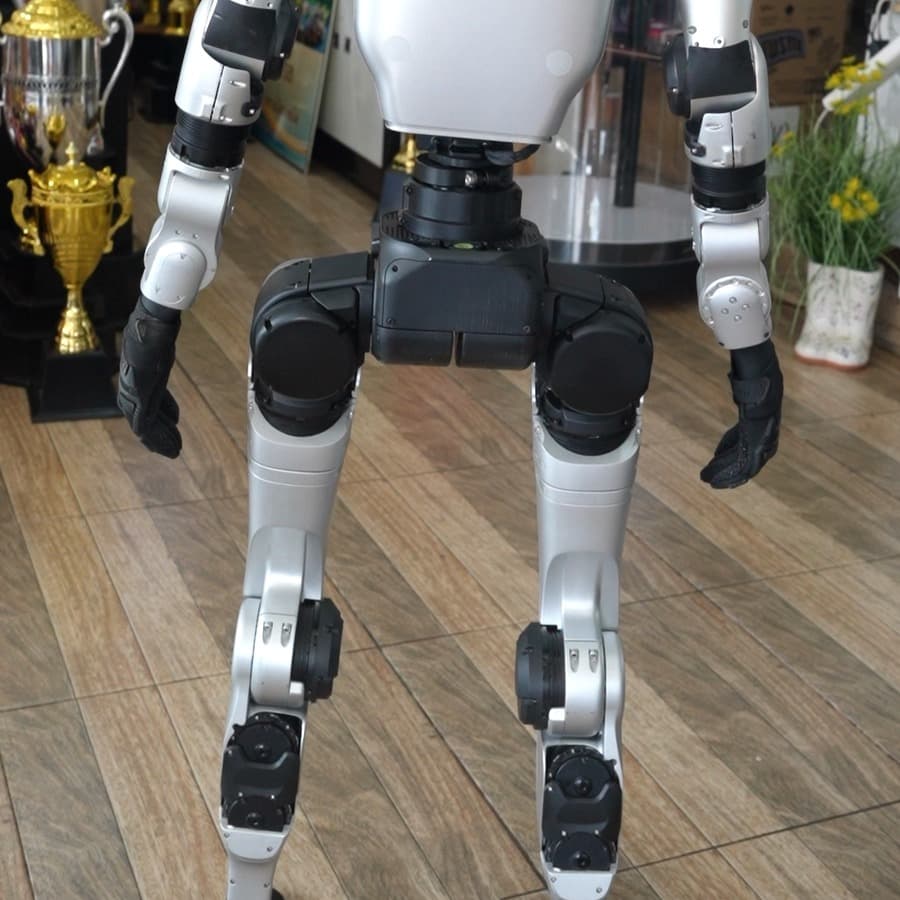
Photo: Thaibotic, Pathum Thani, November 2026


